Imagine a robot working on a factory floor. It picks up a fragile component, applies too much pressure, and damages it. A traditional system might repeat the same action the next time it encounters a similar situation unless someone changes its instructions. But what if the robot could recognize what went wrong, learn from the experience, and make a better decision the next time?
This is one of the most interesting questions in modern robotics: Can robots learn from human mistakes instead of repeating them?
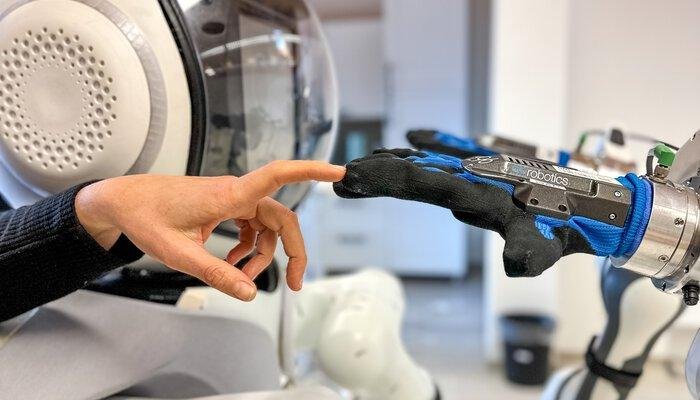
As robots become more capable of working alongside people, researchers are exploring ways to help machines learn from demonstrations, feedback, previous failures, and real-world experience. The goal is not simply to make robots follow instructions. It is to help them adapt when something unexpected happens.
Although robots cannot learn from mistakes exactly as humans do, advances in machine learning, reinforcement learning, and imitation learning are bringing this possibility closer to everyday applications.
Why Human Mistakes Matter in Robotics
Human mistakes often reveal something that was missing from the original plan. A worker might use the wrong tool, overlook a safety warning, or discover that a process does not work as expected. Each situation can provide useful information about how a task should be performed differently.
Robots can benefit from similar information.
For example, a warehouse robot might struggle to move a package because its shape is unusual. Rather than treating every failed attempt as an isolated event, a learning system could use information about the package’s shape, weight, and movement to improve its next attempt.
Human mistakes can also help developers identify weaknesses in robotic systems. If a robot repeatedly misunderstands a hand gesture or struggles to recognize an object in poor lighting, those failures can reveal where its training data or decision-making process needs improvement.
However, there is an important distinction: learning from a mistake does not automatically mean understanding why it happened. A robot needs suitable feedback, reliable data, and a learning method capable of connecting an action with its outcome.
How Can Robots Learn From Human Errors?
Several artificial intelligence techniques can help robots improve their behavior by learning from human actions and mistakes.
1. Learning Through Human Demonstrations
Imitation learning allows a robot to learn how to perform a task by observing examples of human behavior. Instead of programming every movement individually, developers can demonstrate how a task should be completed.
Consider a robot designed to assemble electronic components. A human worker demonstrates the correct placement of a part, including how much pressure to apply and where to position it. If another demonstration shows an unsuccessful attempt, the system may also learn which movements should be avoided.
The quality of this learning depends on the examples provided. If the robot observes only successful demonstrations, it may not know how to respond when a familiar task goes wrong. Carefully selected failure examples and corrections can make its learning more useful.
2. Improving Through Trial and Error
Reinforcement learning trains an agent to select actions based on feedback about their outcomes. In robotics, that feedback may reward successful actions and discourage unsafe or ineffective ones.
Imagine a robot learning to navigate a cluttered room. It initially chooses a route that leads to a dead end. With an appropriate training setup, it can receive feedback and learn to prefer a more effective route in similar situations.
This process can require many attempts, however. Allowing a physical robot to learn through uncontrolled trial and error can be expensive or dangerous. Researchers therefore use simulations, restricted test environments, and safety constraints to reduce the risks.
3. Learning From Human Corrections
Sometimes, a small correction is more valuable than a lengthy instruction.
Suppose a robot assisting in a laboratory reaches for the wrong container. A human operator stops the movement and indicates the correct one. A learning system can use this feedback to improve its future decisions, depending on how it is designed and trained.
Human feedback can take several forms, including verbal instructions, corrected demonstrations, labeled examples, and direct intervention. These signals can help robots recognize when their behavior does not match human expectations.
Still, one correction does not guarantee that a robot will remember the lesson or apply it in every situation. Developers must ensure that feedback is incorporated into the learning process appropriately.
4. Recognizing Patterns in Repeated Failures
A single failure might be caused by chance, but repeated failures can reveal a pattern.
For instance, a delivery robot may repeatedly misjudge the distance between itself and a low obstacle. Analyzing these incidents could reveal that its sensors perform poorly under particular lighting conditions or that its obstacle-detection model needs additional training.
By identifying recurring problems, engineers can update the robot’s perception system, improve its training data, or revise its operating rules.
The important lesson is that robots do not need to eliminate every failure immediately. They need reliable ways to identify failures, understand their likely causes, and reduce the chance of repeating them.
Where Could Mistake-Learning Robots Make a Difference?
Robots that improve through feedback and experience could benefit several industries. Their effectiveness will depend on the task, the quality of their learning systems, and the safety measures surrounding them.
Manufacturing and Industrial Automation
Manufacturing environments often involve repetitive tasks where small errors can damage products or interrupt production.
A robot that detects an incorrectly positioned component could flag the issue and use the information to improve future handling. In a controlled production environment, this could help reduce repeated assembly errors, material waste, and unnecessary downtime.
Human supervisors would still need to validate important changes, especially when product quality or worker safety is involved.
Healthcare and Assistive Robotics
Healthcare robots may assist with moving equipment, delivering supplies, or supporting people with limited mobility. In these settings, mistakes can have serious consequences.
Learning from supervised demonstrations and corrections could help a robot improve its movements and respond more appropriately to its surroundings. For example, a robot might learn to approach a person more slowly when operating in a crowded room.
Such systems require strict safeguards, appropriate testing, and human oversight. A robot should not independently experiment with actions that could put a patient at risk.
Warehousing and Logistics
Warehouses contain moving workers, changing layouts, stacked packages, and objects of different sizes. These conditions make it difficult to anticipate every possible situation.
A warehouse robot could learn from instances where it misjudges a package, selects an inefficient route, or struggles to grasp an item. Over time, suitable training and feedback could help it handle similar situations more effectively.
The result could be more dependable material handling and fewer repeated operational problems.
Agriculture and Outdoor Robotics
Agricultural robots work in environments that change with the weather, soil conditions, plant growth, and uneven terrain.
A robot designed to identify weeds, monitor crops, or harvest produce may encounter conditions that differ from its training examples. Learning from corrected classifications and unsuccessful attempts could improve its performance across changing conditions.
Nevertheless, learning must be carefully evaluated. An incorrect identification could damage a crop or cause a robot to overlook a plant that needs attention.
The Difference Between Learning From Errors and Simply Repeating Them
A robot can collect large amounts of data without necessarily becoming better at its job. The quality of its learning process matters more than the number of mistakes it records.
For meaningful improvement, a robotic system generally needs to complete several steps:
- Detect the failure: Recognize that an action did not produce the intended result.
- Collect relevant information: Record useful details about the action, environment, and outcome.
- Identify a likely cause: Determine whether the problem involved perception, planning, control, or incomplete instructions.
- Receive feedback: Use a reliable signal, such as a human correction or a measured outcome.
- Improve and test: Update the relevant behavior and evaluate whether the change actually helps.
- Monitor future performance: Check whether the problem becomes less frequent without introducing new risks.
This process is not always straightforward. A robot may incorrectly identify the cause of a failure, learn from misleading feedback, or improve one task while performing worse on another.
That is why careful testing and performance monitoring remain essential.
What Challenges Still Stand in the Way?
Despite progress in artificial intelligence, robots face several barriers before they can reliably learn from mistakes in everyday environments.
Understanding the Cause of a Mistake
Recognizing that an action failed is different from determining why it failed. A robot that drops an object might have used too much force, encountered a slippery surface, or misjudged the object’s weight.
Without enough information, it may learn the wrong lesson and repeat the problem under slightly different conditions.
Avoiding Unsafe Experiments
Learning through mistakes can be acceptable in a simulation but dangerous in a real workplace. A robot cannot safely test every possible action around people, expensive machinery, or fragile equipment.
Developers must establish boundaries that prevent the learning process from overriding safety requirements.
Adapting to New Situations
A robot may perform well in a familiar environment but struggle when lighting changes, tools are replaced, or objects appear in unfamiliar shapes.
This challenge, often associated with generalization, highlights the difference between memorizing examples and applying useful knowledge to new situations.
Protecting Data and Human Trust
Robots that learn from people may collect video, movement records, voice commands, or workplace performance data. Organizations need to consider privacy, access controls, data retention, and the appropriate use of recorded information.
Workers should also understand when a robot is learning, what information it collects, and how its behavior may change.
Can Robots Learn Without Making the Same Mistake Again?
Robots can be designed to reduce repeated mistakes, but completely eliminating them is a much harder goal.
A system may learn to avoid a particular error in one environment and still encounter a different version of the problem elsewhere. New conditions, incomplete data, sensor limitations, and unexpected interactions can all lead to fresh failures.
One promising approach is to combine learning with established safety rules. A robot can improve its performance through demonstrations and feedback while remaining restricted from actions that violate defined safety limits.
Simulation also offers a useful way to investigate failures before testing solutions in the real world. Developers can reproduce difficult scenarios, compare different approaches, and evaluate whether an updated model behaves more reliably.
The strongest systems will not simply learn to avoid yesterday’s mistake. They will be designed to recognize uncertainty, ask for help when necessary, and operate within clearly defined boundaries.
The Future of Robots That Learn From Human Mistakes
As robotics and artificial intelligence continue to develop, learning from errors may become an increasingly important part of making machines more adaptable and dependable.
Future robots could use a combination of human demonstrations, corrective feedback, simulation, sensor data, and performance evaluation to improve their behavior. In workplaces, this could help machines respond to changing conditions rather than relying entirely on fixed instructions.
However, progress will require more than smarter algorithms. Organizations will need transparent learning processes, careful evaluation, privacy protections, and practical ways for people to supervise robotic systems.
Human mistakes have always provided opportunities to improve how work gets done. When robots can use those lessons responsibly, failures may become valuable signals for improvement rather than problems that keep happening.
The real breakthrough will not be a robot that never makes a mistake. It will be a robot that can respond to mistakes intelligently, learn from reliable feedback, and become safer and more useful over time.
Frequently Asked Questions
1. Can robots learn from human mistakes?
Yes, robots can learn from human corrections, demonstrations, feedback, and previous failures when they are designed with suitable machine learning systems.
2. How do robots learn from their mistakes?
Robots can use imitation learning, reinforcement learning, and human feedback to identify errors, improve decisions, and perform tasks more effectively.
3. Which industries can benefit from robots that learn from errors?
Manufacturing, healthcare, agriculture, and warehousing can benefit from robots that learn from feedback and reduce repeated mistakes.
4. Can robots completely avoid repeating mistakes?
No, robots cannot guarantee error-free performance. However, proper training, reliable feedback, testing, and safety controls can help reduce repeated errors.